V3 ESP32 Car
1. Introduction
The v3 remote control car uses a metal body, an ESP32 main controller, and encoder motors, enabling precise control with a large load capacity. It has the following advantages:
-
The aluminum alloy body has high load-bearing strength and is easy to drill for installing expansion modules;
-
The ESP32-S3 driver board is based on the mature Arduino architecture, and we provide rich example code and hardware interfaces for easy secondary development;
-
The factory code has been optimized, so it works right out of the box.
2. Initial Configuration
① Please assemble according to the video above: the wheels are left-right specific; if the wheels are not assembled as shown in the video, driving will be affected.
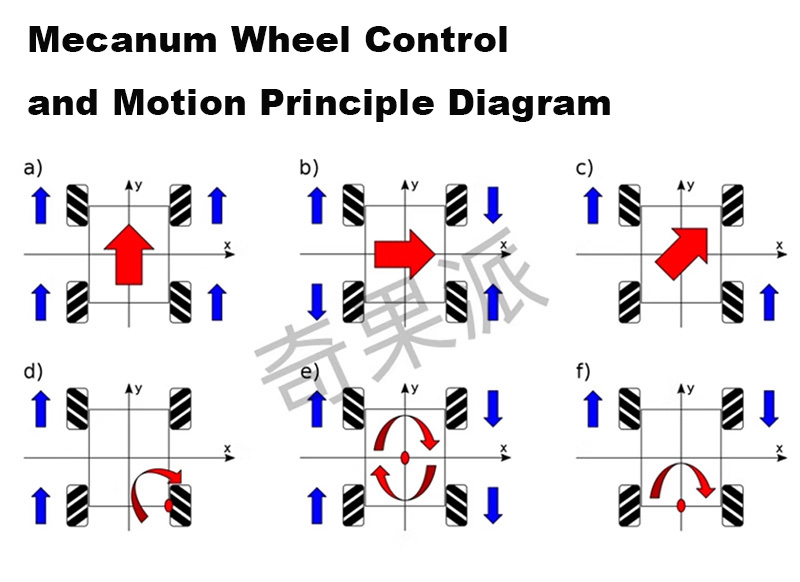
② For the first pairing of the remote controller, hold the X key and then short-press the Home key to power on; the No. 4 light staying on indicates it is connected;
③ Ensure the wiring order of the 4 motors:
Front-left wheel to M1, front-right wheel to M2

Rear-left wheel to M3, rear-right wheel to M4
④ Push the left joystick forward; all 4 wheels should rotate forward. If not, swap the positive and negative terminals of that motor's power cable until all 4 wheels rotate forward;
⑤ After completing step 3, single-click the remote controller's Start key; the car will move forward for a distance while it automatically identifies the hardware and initializes the configuration;
⑥ The configuration is now complete; you can control the car according to the remote controller instructions at the bottom of this document.
3. Load Capacity Notes
The maximum tested load of 25 kg is measured with a full battery and motors with a 1:90 gear ratio. For long-term use, to extend the service life of the motors and tires, please reduce the load as appropriate:
-
1:90 motor: recommended within 15 kg
-
1:30 motor: recommended within 8 kg
4. Remote Controller Instructions
The following code is developed based on the VSCode + PlatformIO environment.
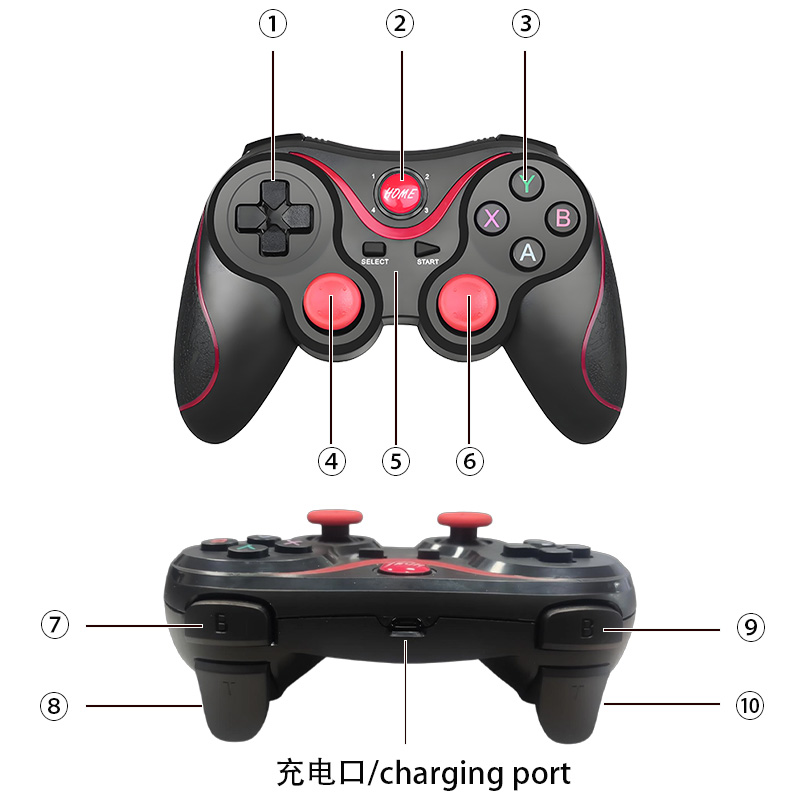
- ①Directional pad:
- Left/right: controls the forward/reverse rotation of servo No. 1;
- Up/down: controls the forward/reverse rotation of servo No. 2;
- ②Home key: short-press to power on, long-press to power off; it will power off automatically after a long period of no operation;
- The No. 4 light being on indicates the correct communication mode. If another light is on, power off, then hold the X key and short-press the Home key to power on to switch to mode 4;
- No. 4 light blinking: indicates it is connecting; No. 4 light staying on indicates a connection has been established with the device.
- Multiple lights blinking: indicates a low battery state; please plug the USB cable into a computer or other charger to charge.
- ③ The four A/B/X/Y buttons:
- X and B control the forward/reverse rotation of servo No. 3;
- Y and A control the on/off of pin 45;
- ④Left joystick: vehicle control
- Single-click: engage the parking brake
- Mecanum wheel mode: calculates the vehicle speed based on the joystick's tilt: forward/backward and left/right lateral movement
- Normal mode: calculates the vehicle speed based on the joystick's tilt: forward/backward and left/right turning
- ⑤Auxiliary keys
- SELECT: press to switch the control mode (Mecanum mode/normal mode); Mecanum mode by default
- START: vehicle self-check
- ⑥Right joystick
- Single-click: release the parking brake
- Mecanum mode: calculates the vehicle speed based on the joystick's tilt: left/right turning
- Normal mode: idle
- ⑦Right index-finger B key: increase the maximum speed — the maximum motor speed when the joystick is pushed to the limit (each press increases it by 5%);
- ⑧Right index-finger T key: controls the forward rotation of servo No. 4;
- ⑨Left index-finger B key: decrease the maximum speed — the maximum motor speed when the joystick is pushed to the limit (each press decreases it by 5%);
- ⑩Right index-finger T key: controls the reverse rotation of servo No. 4.